# yaris-obd
A Raspberry Pi 3-based OBD-II, GPS, and dashcam system for a 2013 Toyota Yaris. Reads live
vehicle data over USB, tracks position with a SIM868 GNSS/GSM HAT, logs everything locally, and
serves a web UI over the car's own WiFi hotspot. The dashboard and pre-cached map work fully
offline, while trip data and dashcam footage sync to a self-hosted remote server whenever an
internet uplink is available.
**Open source** — released under the [MIT License](LICENSE). Contributions welcome.
[](LICENSE)
**rené lévesque bangers**
i have a dream
[](https://open.spotify.com/playlist/5u9vSw39FrIz7KghBkmgH4)
## Screenshots
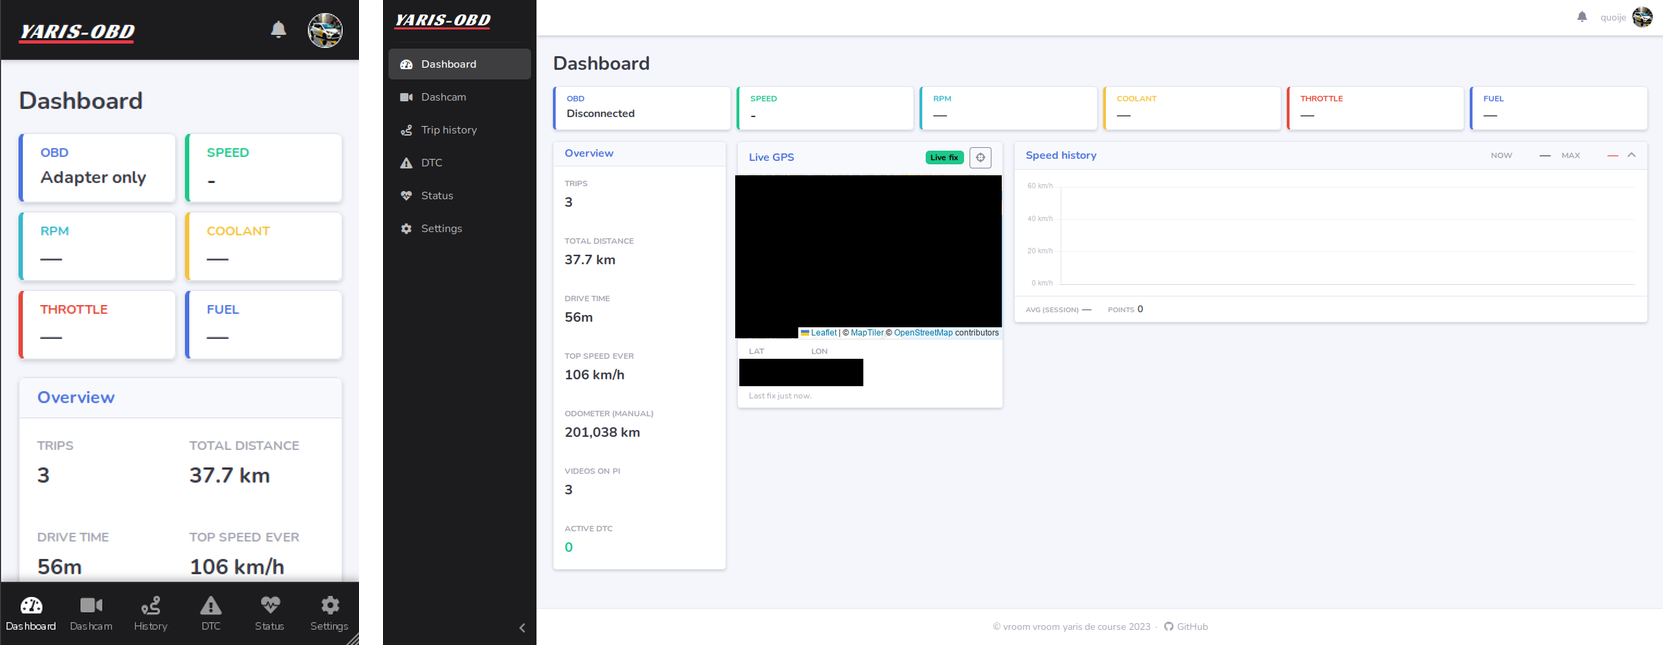
Dashboard — mobile (390 px) and desktop (1280 px):
## Features
- **Live OBD-II data** — speed, RPM, coolant temp, fuel level, throttle, MIL/DTC via USB ELM327.
Automatic reconnects with clear adapter/ECU diagnostics. DTC codes persist across reboots and
can be cleared straight from the DTC page.
- **Real GPS tracking** — Waveshare SIM868 GNSS HAT with GPIO PWRKEY auto-power-on. Live position
plotted on an offline Leaflet map (pre-cached tiles, no internet needed).
- **WiFi hotspot** — fast 5GHz in-car AP on a T3U (wlan1), internet uplink (home WiFi +
phone hotspot) on a second T3U (wlan2); the onboard radio is a fallback. SSID/password configurable from the Settings page.
- **Dashcam workflow** — auto-detects any USB dashcam, mounts read-only, browses files before
importing. Import one, selected, or all files. Delete individual or all files directly from the
dashcam. Verified against real 28GB/87-file hardware.
- **Local video library** — browse imported clips with cached thumbnails and upload status. Inline
H.264 playback with seeking. Local-only delete. Optional auto-retention after confirmed upload.
- **Remote sync** — trip logs and dashcam footage upload to a self-hosted Flask + Postgres server.
Dashcam videos stream in resumable 40MB chunks. Independent toggles for trip and dashcam uploads.
- **Remote web portal** — login-protected at the server URL. Trip history with CARTO live map and
route replay, dashcam archive with inline player, overview stats, device management
(create/delete/rotate keys), and server-side device identity sync that hot-reloads on the Pi.
- **Trip history and replay** — motion-aware detection (OBD wheel speed primary, GPS displacement
fallback). Metric summaries, offline route polyline, play/pause timeline with moving marker and
live reverse-geocoded location names. Tap-to-replay on mobile. Captures OBD speed before the
first GPS fix so rolling starts aren't lost.
- **Status page** — Pi health (temp, RAM, disk, uptime, throttling), service states, uplink/server/
GPS/OBD diagnostics, and quick actions (test server, sync now, reconnect uplink, restart app).
- **Offline-first alerts** — notification bell on every page for check-engine, storage pressure,
upload backlog, temperature/power faults, and GPS loss while moving. Optional ntfy push.
- **Manual odometer** — Pi Settings page accepts a baseline reading; dashboard computes
`odometer = baseline + trip distance`. Synced to the remote server; portal shows read-only value.
- **Device config sync** — server-side owner name, car model, display name, avatar path, and sync
toggle hot-reload on the Pi without restart. Multi-device management on the portal with
create/rotate/delete keys and one-time API-key reveal.
- **Reverse geocoding** — `/api/geocode` uses `reverse_geocoder` offline (no internet needed),
upgrades to Nominatim street-level when online. LRU-cached. Results pre-loaded for trip scrubbing.
- **Android companion app** — native Kotlin app in `android/` (Phase 28, in progress). Dual-network
on the phone: browse + download dashcam clips over the car's WiFi, relay uploads over cellular.
Networking gate + dashcam browser/download verified on a Pixel; cellular upload in progress.
- **Offline web UI** — Flask, Bootstrap 5, Socket.IO, Chart.js, Leaflet. All assets served
locally. Responsive with collapsible sidebar and mobile bottom nav.
- **Headless deployment** — systemd service with auto-restart, 10-second hardware watchdog, and
nftables port-80 redirect. Deploy scripts in `deploy/`.
## Hardware
| Part | Notes |
| --- | --- |
| Raspberry Pi 3 Model B Rev 1.2 | Web UI host, logger, uploader, and WiFi hotspot |
| Waveshare SIM868 HAT | GNSS (GPS) + optional GSM/GPRS uplink, unused Bluetooth |
| USB OBD-II adapter | PL2303-based, ELM327-compatible (originally Bluetooth, switched to USB) |
| DS3231 RTC module | Battery-backed real-time clock on I²C (`i2c-1`, 0x68) — keeps trip timestamps correct with no internet |
| Power | Regulated 5V hard-wired to GPIO pins 2 & 6 (red/black), fed from a fused 12V→5V source — bypasses the worn micro-USB port |
| 2× TP-Link Archer T3U (RTL8812BU) | USB WiFi dongles — AC1300 dual-band. wlan1 hosts the 5GHz in-car AP; wlan2 carries the internet uplink since 2026-08-14 |
| Onboard BCM43438 (wlan0) | Fallback only — was the internet uplink until 2026-08-14 |
| USB dashcam | Any brand — detected as generic USB mass storage |
| 2013 Toyota Yaris | The patient |
See [PLAN.md](./PLAN.md) for full hardware bring-up notes (SIM868 jumper/UART setup, antenna
gotchas, etc.) and the detailed project history.
## Getting started
```bash
python3 -m venv venv
source venv/bin/activate
pip install -r requirements.txt
python3 app.py
```
The app serves on `http://:5000`. On the Pi it runs as a `systemd` service and is reachable
with no port number at `http://yaris.local` after installing the mDNS and port-redirect setup.
Deployment helpers for the app service, hotspot watcher, port redirect, and hardware watchdog are
in [deploy/](./deploy). For a **full hardware → software build walkthrough** on a fresh Pi —
including the one-shot `deploy/auto_install.sh` installer — use
[deploy/readme.md](./deploy/readme.md). See [PLAN.md](./PLAN.md) for the full hardware/project history.
For the remote server (receives trip logs + dashcam uploads), see [server/README.md](./server/README.md).
## Project status
The Pi app, remote server, device sync, and the Android companion app are all implemented and
verified on real hardware:
- **Phase 25** — real-car road test ✅
- **Phase 26** — road-test bug fixes (14 bugs) ✅
- **Phase 27** — feature additions: DTC history sync, manual odometer, hotspot settings +
5GHz WiFi swap, trip-history odometer ✅
- **Phase 28** — Android companion app ✅ — networking gate, dashcam browser/download,
cellular upload, live dashboard, trip history, remote portal, UI redesign, and signed APK
distribution. End-to-end cellular upload on the owner's Pixel is the last item pending final
verification.
- **Phase 29** — round-2 road-test bug fixes 🚧 in progress.
Full phase history and verification notes live in [PLAN.md](./PLAN.md). Open issues in
[BUGS.md](./BUGS.md). Feature requests in [FEATURES.md](./FEATURES.md).
## Diagnostics & recovery
If something goes wrong in the car, SSH in and run:
```bash
bash ~/app/yaris-obd/scripts/diagnose.sh # read-only health check
bash ~/app/yaris-obd/scripts/diagnose.sh --fix # attempt auto-fix
```
Checks service state, OBD/UART hardware, disk/DB health, upload backlog, Pi throttling, and
prints a cheatsheet of recovery commands. Exit code = number of critical issues found.
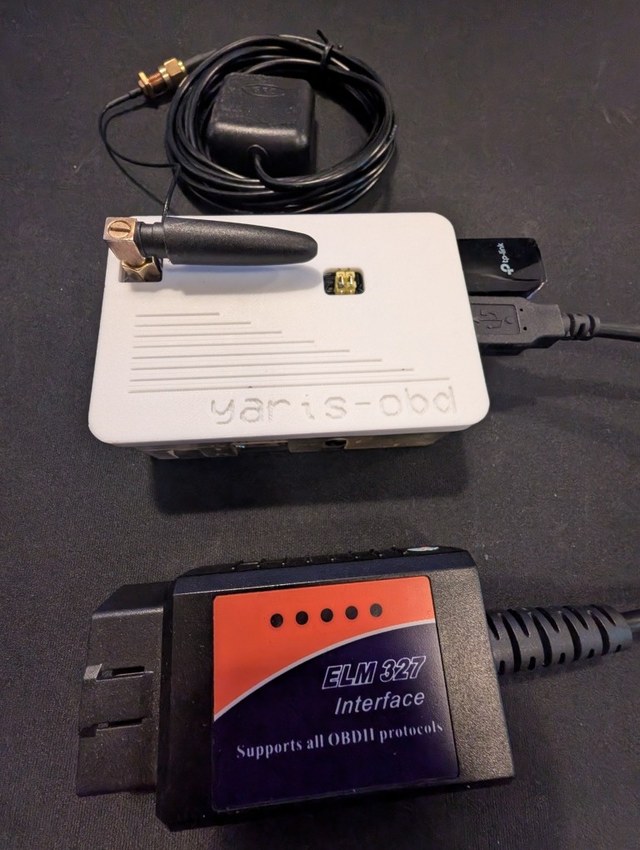
## Hardware photo
## License
This project is open source and released under the [MIT License](LICENSE).